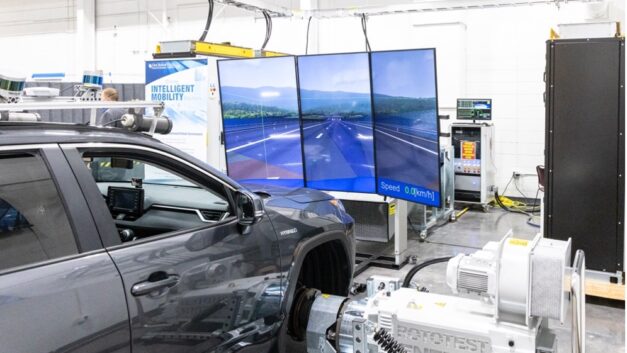
Hanlin (Julia) Chen earned her Ph.D. in Computer and Information Technology and her Master of Science in Mechanical Engineering Technology from Purdue University in 2021 and 2016, respectively. Julia’s research area includes but is not limited to cooperative perception, digital twin, perception-based CDA, cybersecurity for CAV, and CAV’s impact on homeland security. Her passion for connected and automated vehicles led her to MCity at the University of Michigan. She was a visiting graduate student at MCity in the summer of 2018.
She has published several high-quality papers in top journals and conferences, such as IEEE Transactions on ITS and Conference on Computer Vision and Pattern Recognition (CVPR). She is a member of IEEE and ACM, and a member of Transportation Research Board, Standing Committee on Transportation System Resilience and Security (ACF18)
Links
Publications
Aug, 2026
Conference Paper
ObstacleSense: Low-Power Neuromorphic Vision for Corridor Obstacle Awareness in Low-Level ADAS
Mar, 2026
Conference Paper
Emerging Threats in Transportation Security Related to Intelligent Transportation Systems (ITS)